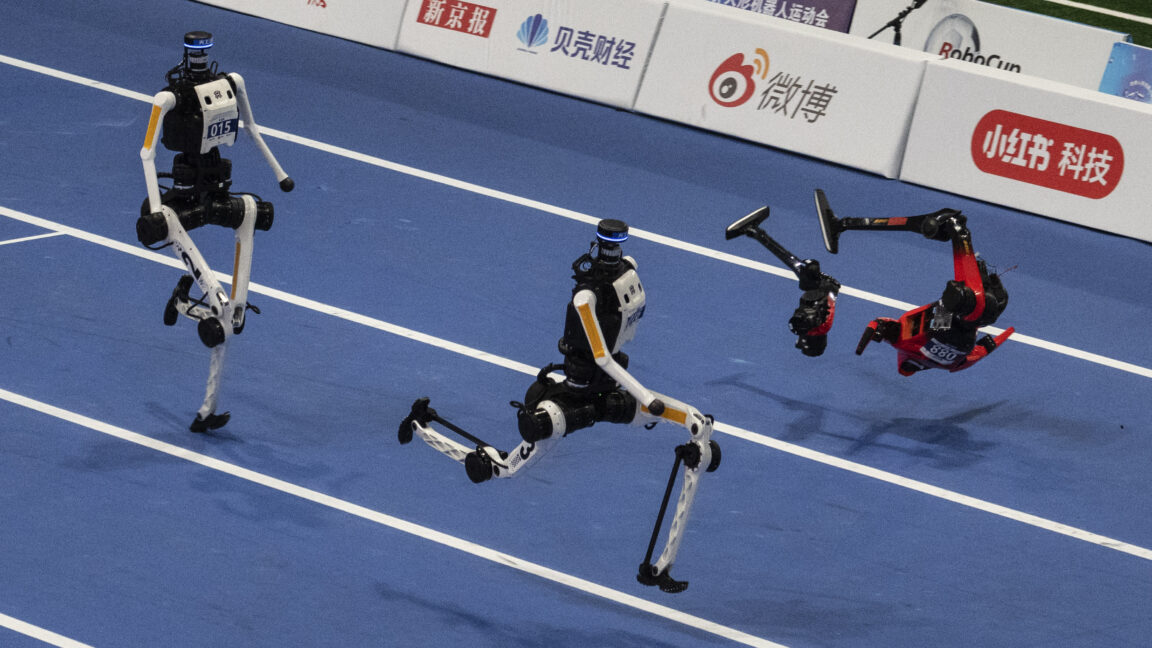
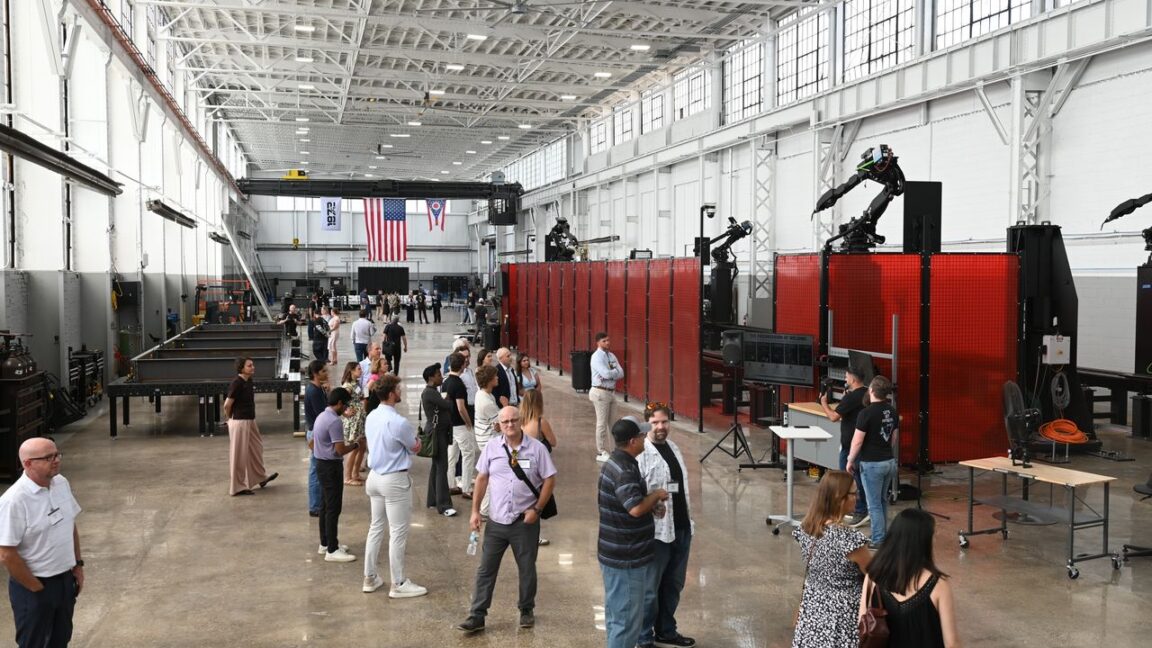
News / #robotics Tag Robotics 500 articles archived under #robotics · RSS Sign in to follow TechCrunch — AI news-outlet 1mo ago Robot brain builders are pushing out of their GPT-2 era Robot bodies are waiting for their AI brains to catch up. 6 Hugging Face Daily Papers research 1mo ago Latent Action as Intention Enables Efficient Future Imagination for World Action Models Abstract LAWA improves robot control by using compact latent actions to retain efficient future imagination without generating observations, achieving strong performance with lower latency. Generated by thinkingmachines/Inkling-Small World action models (WAMs) improve robot… 6 TechCrunch — AI news-outlet 1mo ago Robotics startup Generalist reaches $3B valuation, sources say The $200 million extension comes just months after the physical AI startup reached a $2 billion valuation. 27 Ars Technica — AI news-outlet 1mo ago World humanoid robot games show runners breaking records, bursting into flames Record-breaking robot races are less substantial than household chore challenges. 12 MIT Technology Review — AI news-outlet 1mo ago I spent a day at a robot “carnival” in Shanghai. Here’s what I saw. Humanoid robots are having a moment in China. The popular machines are part of the country’s strategy to bring artificial intelligence into daily life. Embedding the technology into physical systems—an idea called embodied AI—was a key facet of China’s latest five-year plan, and… 28 arXiv — NLP / Computation & Language research 1mo ago Whitewashing Hate, Smearing Harmless Content: Annotator-Style Rebuttal Attacks on LLM-Based Moderation arXiv:2608.22230v1 Announce Type: new Abstract: Large language models (LLMs) are increasingly used for hate speech moderation, often within human--AI workflows in which reviewers provide feedback before a final decision. Such feedback introduces two manipulation directions:… 35 Hugging Face Daily Papers research 1mo ago PhysCaP: Grounding Code-as-Policy Agent with Physics-Informed Exploration Abstract PhysCaP is a physics-informed code-generation agent that actively explores objects to infer hidden physical properties for efficient robotic manipulation. Generated by thinkingmachines/Inkling-Small We present PhysCaP, a Physics-Informed Code-as-Policy agent for active… 11 TechCrunch — AI news-outlet 1mo ago Valor, Point72 back General Intuition at $6B valuation as AI startup pushes into robotics General Intuition, the startup building a foundation model that trains generalized AI agents how to move through space and time, is in talks to raise at a $6 billion pre-money valuation from new investors including Valor Ventures, Point72 Ventures, Seven Seven Six. 19 Hugging Face Daily Papers research 1mo ago Hydra-0: Action Flow for Generalist World Modeling and Control Abstract Hydra-0 uses action flow as a shared visual interface for generalist world modeling and robot control across diverse embodiments and tasks. Generated by thinkingmachines/Inkling-Small We introduce Hydra-0, a generalist world model conditioned on action flow, which… 21 Smol AI News news-outlet 1mo ago not much happened today **Microduck**, a **25 cm open-source biped robot** from **Pollen Robotics** and **Hugging Face**, priced at **$399** and shipping before Christmas, features **15 actuators** and a rich sensor suite including camera, LiDAR, NFC, Bluetooth, and Wi-Fi. It supports… 32 arXiv — Machine Learning research 1mo ago Keyed Provenance Watermarking with Complementary Lattice-Based Secure Aggregation for Federated Learning arXiv:2608.20580v1 Announce Type: cross Abstract: Federated learning (FL) is vulnerable to multi-level attacks. However, existing methods address them separately, leaving FL exposed to data leakage, unauthorized reuse, and malicious gradient manipulation. In this work, we… 26 arXiv — Machine Learning research 1mo ago Rethinking Demonstration Unlearning in Imitation Learning for Robotics arXiv:2608.20784v1 Announce Type: cross Abstract: Imitation learning for robotics depends on human demonstrations, some of which people may later ask to remove. Retraining without them is the natural reference, but its cost grows with policy and dataset scale, motivating cheaper… 12 The Information — AI news-outlet 1mo ago Why Unitree’s 460% IPO Stock Pop Wasn’t Unusual in China Humanoid robot maker Unitree’s 460% surge in its Shanghai stock market debut on Wednesday was the latest in a series of eye-watering first trading-day pops fetched by some recent tech initial public offerings in mainland China’s stock market. It followed last month’s debut of… 37 The Information — AI news-outlet 1mo ago America Really, Really Hates Data Centers • The Big Read: AI promises to cure cancer. Scientists feel existential dread • The new robotics ‘ arms race ’: Who can do the craziest hype video? • Plus, Recommendations—our weekly pop culture picks: “ Dan Taberski’s Manifesto ,” “ A Tender Age ” and “ The End of Oak Street ”… 18 Hugging Face Daily Papers research 1mo ago τ_0-VLA: a Hierarchical Robot Foundation Model with World-Model-Guided Test-Time Computation Abstract A hierarchical vision-language-action model improves long-horizon robot manipulation by using world-model-guided test-time search to scale computation for high-level subtask decisions. Generated by thinkingmachines/Inkling-Small Long-horizon robot manipulation requires… 5 The Information — AI news-outlet 1mo ago The New Robotics ‘Arms Race’: Who Can Do the Craziest Hype Video? A couple months ago, a humanoid robot was dispatched to the top of Ecuador’s Mount Chimborazo, the surface point farthest from the center of the planet. It was a stunt arranged by Geologic Dome, a nonprofit that uses AI and robotics for nature conservation, which had obtained… 8 Hugging Face Daily Papers research 1mo ago GOAG: Generative and Object-Agnostic Grasp Planner for Dexterous Robotic Manipulation Abstract GOAG is an object-agnostic deep generative grasp planner that learns a gripper-specific contact surface distribution to sample valid grasps for unseen objects without object-specific training. Generated by thinkingmachines/Inkling-Small Multifingered grasping is a… 35 Hugging Face Daily Papers research 1mo ago EXIMO: VLM Guided Exploration of VLA Policies Abstract EXIMO efficiently fine-tunes large vision-language-action robot policies by combining VLM-guided exploration, imitation on orchestrated data, and residual off-policy reinforcement learning. Generated by thinkingmachines/Inkling-Small How to efficiently finetune robot… 6 arXiv — Machine Learning research 1mo ago SCAPE: Scenario-Conditioned Simulation-Augmented Policy Evaluation arXiv:2608.19425v1 Announce Type: cross Abstract: Reliable performance evaluation is a central bottleneck for deploying robot-learning policies in real-world conditions. Real-world testing is faithful but costly and difficult to scale, whereas simulation-based testing scales… 6 arXiv — Machine Learning research 1mo ago Fine-Tuning VLAs with Self-Demonstrated Generative Control for Multi-Task Manipulation arXiv:2608.19490v1 Announce Type: cross Abstract: State-of-the-art vision-language-action (VLA) models such as $\pi_{0.5}$ exhibit strong semantic understanding, instruction following and task behavior. However, when deployed on new robots, even minor mismatches in hardware… 5 arXiv — NLP / Computation & Language research 1mo ago NepOOC-M: Bilingual Nepali-English Benchmark and Comparative Analysis of Multimodal Architectures for OOC Detection arXiv:2608.19212v1 Announce Type: new Abstract: Out-of-context (OOC) misinformation pairs authentic images with misleading captions to construct false narratives without image manipulation, making detection a problem of multimodal alignment rather than image forensics. Despite… 20 The Information — AI news-outlet 1mo ago Robots Are in Their GPT-2 Era It’s no secret that AI-powered robots aren’t so good yet. They struggle with a broad range of simple tasks, from untangling cables to chopping vegetables. Nonetheless, morale is high among roboticists who are flush with venture cash as they work toward a “ ChatGPT moment ” when… 4 arXiv — Machine Learning research 1mo ago Allocating Recurrent Compute in Looped Language Models arXiv:2608.18230v1 Announce Type: new Abstract: Looped language models improve reasoning and knowledge manipulation by applying shared computation repeatedly. Existing systems usually repeat an entire layer stack, although a mixer and a dense feed-forward network (FFN) perform… 12 arXiv — Machine Learning research 1mo ago FedLNS: Leverage LayerNorm Signature Modeling to Mitigate Adversarial Manipulation in Federated LLMs arXiv:2608.18736v1 Announce Type: new Abstract: Federated training enables language models to learn from distributed private text, but the server cannot directly verify the local supervision or optimization process that produces each client update. A malicious client can… 25 arXiv — NLP / Computation & Language research 1mo ago MicroPython and CircuitPython: Pythons Quiet Takeover of IoT and Robotics arXiv:2608.18160v1 Announce Type: cross Abstract: Background: Python has become the dominant language in software and data science, yet embedded systems have remained tied to C/C++ due to performance and memory constraints. MicroPython and CircuitPython are changing this by… 26 arXiv — NLP / Computation & Language research 1mo ago Multimodal Rapport Estimation in Real-World HRI arXiv:2608.18401v1 Announce Type: cross Abstract: Evaluating interaction quality in real-world HRI is an important challenge. If interaction quality can be estimated reliably, the results can be used to improve dialogue strategies and ultimately enable robots to adapt their… 28 Hugging Face Daily Papers research 1mo ago Zetta ζ: An Efficient Closed-Loop Embodied Harness for Self-Evolving Physical Intelligence Abstract Zetta is a closed-loop embodied harness that evolves runtime critics and recovery skills online to govern physical execution at action frequency, achieving high success on robot benchmarks with faster inference and scaling self-exploration. Generated by… 36 Hugging Face Daily Papers research 1mo ago SoftVTBench: A Deformation-Aware Visuo-Tactile Dataset and Benchmark for Deformable-Object Manipulation Abstract SoftVTBench introduces a synchronized visuo-tactile dataset and deformation-aware benchmark for evaluating physical interaction quality during deformable-object manipulation. Generated by thinkingmachines/Inkling-Small Physical interaction quality is central to… 24 NVIDIA Developer Blog official-blog 1mo ago Developing NVIDIA Holoscan Applications with CLI, Skills, and AI Coding Agents NVIDIA Holoscan is a platform for building real-time AI applications at the edge, from medical imaging to robotics. HoloHub is its companion repository: a... 18 NVIDIA Developer Blog official-blog 1mo ago Post-Train NVIDIA Cosmos 3 Edge for On-Device Robot Control Robots need policies that can adapt to their sensors, environments, and tasks while running on onboard computing hardware. World models offer a foundation for... 24 The Information — AI news-outlet 1mo ago Chinese Humanoid Maker Unitree Shares Soar on Shanghai Debut Shares of Chinese humanoid robot maker Unitree Robotics soared on the debut on the Shanghai Stock Exchange on Wednesday, after raising 6.1 billion yuan ($905 million) in an initial public offering. The shares surged more than seven times its IPO price before closing 460% up,… 20 arXiv — Machine Learning research 1mo ago VLCP: Vision Language Control Policy Closed-Loop Code Replanning for Robot Manipulation arXiv:2608.16978v1 Announce Type: cross Abstract: Turning a frontier vision-language model into a robot policy usually means fine-tuning it to emit an action representation it never saw in pretraining, which throws away much of the reasoning that made the model worth reaching… 13 arXiv — NLP / Computation & Language research 1mo ago FollowUpBot: An LLM-Based Conversational Robot for Automatic Postoperative Follow-up arXiv:2507.15502v1 Announce Type: cross Abstract: Postoperative follow-up plays a crucial role in monitoring recovery and identifying complications. However, traditional approaches, typically involving bedside interviews and manual documentation, are time-consuming and… 5 Ars Technica — AI news-outlet 1mo ago Former SpaceX engineers are building a robotic factory for making steel parts “We're not necessarily building in a dogmatic fashion towards full autonomy.” 36 MIT Technology Review — AI news-outlet 1mo ago What happens when a kid’s robot best friend dies? When Xander first met Moxie, she taught him that when he was anxious, he could calm down by exhaling through his lips so that he buzzed like a bee. They practiced breathing like dragons to manage feeling mad and sniffing like bunnies to boost his energy. But in the six years… 17 Hugging Face Daily Papers research 1mo ago PRM-as-a-Judge 1.5: A Toolkit for Robot Process Assessment Abstract PRM-as-a-Judge 1.5 provides fine-grained process metrics and reliability tools to evaluate embodied robotic models beyond binary success rates. Generated by thinkingmachines/Inkling-Small Fine-grained robotic evaluation matters for understanding embodied models, going… 33 arXiv — Machine Learning research 1mo ago hint$^2$: Hierarchical World Models for Inference-Time Temporal Logic Guidance arXiv:2608.13678v1 Announce Type: cross Abstract: A central goal of robot learning is to enable robots to execute rich instructions specified at runtime. Large-scale language-conditioned policies have made substantial progress toward this goal, yet still struggle with temporal… 4 arXiv — NLP / Computation & Language research 1mo ago Agentic Transaction: Towards ACID-Compliant Agent Systems arXiv:2608.13900v1 Announce Type: cross Abstract: Large language model (LLM) agents are evolving from conversational assistants into autonomous systems that execute long-horizon tasks through reasoning, tool use, code generation, and workspace manipulation. As agents… 20 Hugging Face Daily Papers research 1mo ago HumanTracker: Towards Comprehensive and Human-Aligned Motion Tracking Benchmark Abstract HumanTracker introduces a large-scale benchmark and preference-aligned metric to evaluate humanoid motion tracking based on perceptual quality and physical contact stability. Generated by thinkingmachines/Inkling-Small Humanoid motion tracking is central to… 5 r/MachineLearning community 1mo ago [Career Advice] Final-year in Physical AI / Robotics. How is the market & global hiring for freshers? [D] Hi everyone, I am heading into my final year of my BTech at a tier 1 college in India and just wrapped up a Physical AI internship at a MNC, working heavily with NVIDIA Isaac Sim and OpenFOAM. My background is fully focused on robotics and autonomy. My tech stack includes:… 35 Hugging Face Daily Papers research 1mo ago H2R-Bench: Benchmarking Human-to-Robot Manipulation Video Generation in World Models Abstract H2R-Bench evaluates video generation models on transforming human manipulation videos into robot-centric demonstrations across embodiment constraints and interaction fidelity. Generated by thinkingmachines/Inkling-Small Large-scale manipulation data is essential for… 22 arXiv — Machine Learning research 1mo ago Towards Socially Compliant Navigation in Deep Reinforcement Learning via Proxemics-Based Reward Modeling arXiv:2608.12917v1 Announce Type: new Abstract: Developing effective robot navigation methods in crowded environments is essential for real-world applications. Although recent deep reinforcement learning (DRL) methods have improved navigation performance in crowded environments,… 31 Hugging Face Daily Papers research 1mo ago DreamX-Phi 1.0: Action-Conditioned Video World Model for Robotic Manipulation Abstract DreamX-Phi 1.0 is an action-conditioned video world model for robotic manipulation that uses geometric attention encoding, depth estimation, object masks with a frozen teacher, and distillation to generate faithful future observations. Generated by… 23 Hugging Face official-blog 1mo ago Record, train, and deploy from one place with Strands Agents, LeRobot, and Hugging Face Storage Buckets Back to Articles a]:hidden"> Record, train, and deploy from one place with Strands Agents, LeRobot, and Hugging Face Storage Buckets Enterprise Article Published August 13, 2026 Upvote 4 Sundar Raghavan rsundaraws amazon Steven Palma imstevenpmwork amazon Cagatay Cali cagataydev… 34 Hugging Face Daily Papers research 1mo ago AtlasVLA: Persistent World-Ego State Modeling for Vision-Language-Action Models Abstract AtlasVLA improves embodied AI by replacing reactive control with proactive reasoning via persistent world-ego memory, enabling robust long-horizon manipulation from a single wrist camera. Generated by thinkingmachines/Inkling-Small While Vision-Language-Action (VLA)… 36 arXiv — Machine Learning research 1mo ago MOON: Multi-Objective OrthoNormalized Updates for Multitask Learning arXiv:2608.11749v1 Announce Type: new Abstract: Multi-objective optimization (MOO) has demonstrated significant success in multi-task learning by mitigating task conflicts through gradient manipulation. However, most existing methods flatten model parameters into vectors and… 8 NVIDIA Developer Blog official-blog 1mo ago NVIDIA JetPack 7.2.1 Adds Agentic Video Skills and T3000 Emulation Video is a core data path across NVIDIA Jetson applications, from robotics and intelligent video analytics to industrial automation, healthcare, media... 5 Hugging Face Daily Papers research 1mo ago RynnValue: Scaling Robotic Value Foundation Models with Temporal Distance Abstract RynnValue is a scalable open-source value foundation model for robot manipulation that uses temporal distance instead of preferences or progress to learn generalizable value predictions and improve real-world policy success. Generated by thinkingmachines/Inkling-Small… 28 arXiv — Machine Learning research 1mo ago LUCID: Latent-Skill Unified Control via Imagined Dynamics for Long-Horizon Humanoid Loco-Manipulation arXiv:2608.07746v1 Announce Type: new Abstract: Long-horizon humanoid loco-manipulation requires composing versatile whole-body skills and reliable high-level decision making. Existing methods often coordinate pretrained skills with scripted planners, finite-state machines or… 30 arXiv — Machine Learning research 1mo ago V-Simba: Unleashing the Architectural Potential of RL in Visual Continuous Control arXiv:2608.07870v1 Announce Type: new Abstract: Improving sample efficiency remains a core challenge in reinforcement learning (RL), especially in real-world settings like robotics, where data collection is costly. This challenge is pronounced in visual RL, where… 14 Page 3 of 10 · 500 articles ← Newer Older →