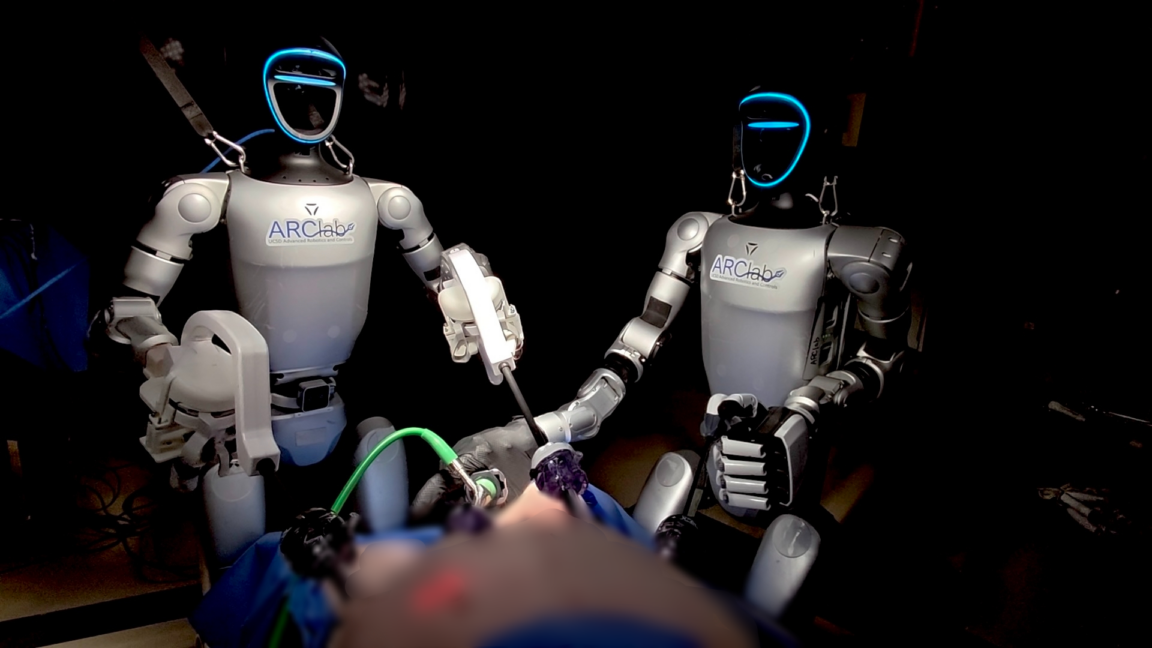
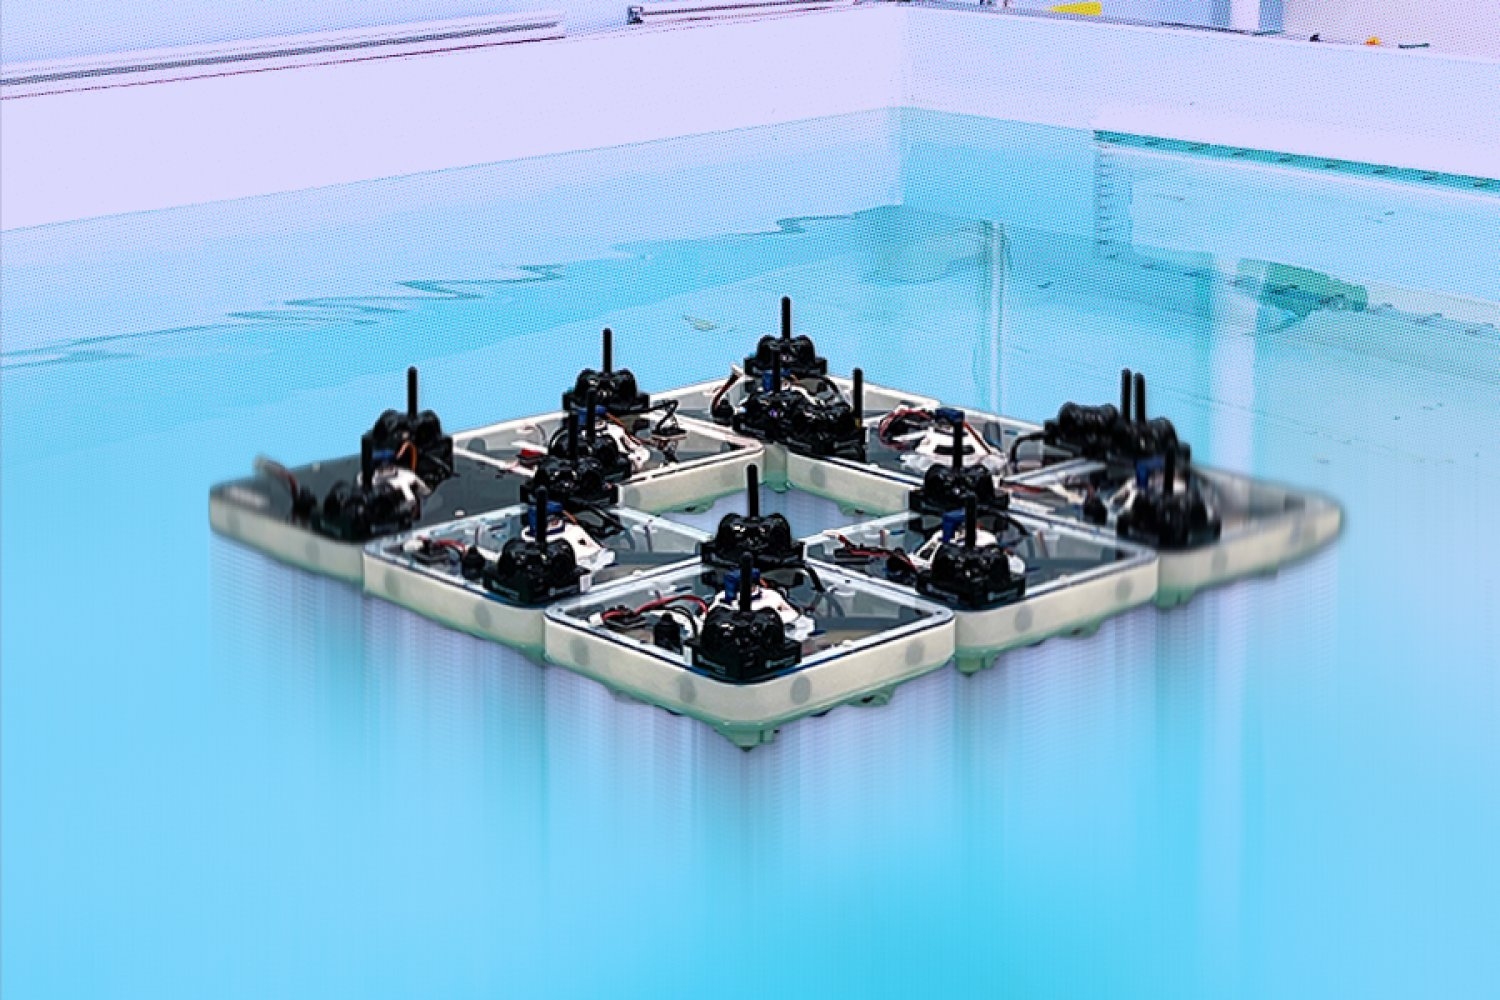
News / #robotics Tag Robotics 500 articles archived under #robotics · RSS Sign in to follow arXiv — Machine Learning research 4mo ago SafeExplorer: An Unbiased Policy Gradient for Reinforcement Learning with Recovery Interventions arXiv:2607.08925v1 Announce Type: new Abstract: Training reinforcement-learning agents directly on physical robots makes every fall costly, since a fall can damage the platform and cannot be undone like a simulator reset; the goal is therefore to minimize falls during training… 8 arXiv — Machine Learning research 4mo ago Learning More from Less: Reinforcement Learning from Hindsight arXiv:2607.09042v1 Announce Type: new Abstract: Reinforcement learning (RL) is increasingly used to post-train vision-language-action (VLA) models, but every update consumes robot rollouts that are slow and costly to collect, making sample efficiency a central concern.… 35 arXiv — Machine Learning research 4mo ago FlowDAgger: Human-in-the-Loop Adaptation of Generative Robot Policies in Latent Space arXiv:2607.08877v1 Announce Type: cross Abstract: Pretrained generative robot policies based on flow matching and diffusion have achieved impressive results across a wide range of manipulation tasks. Yet real-world deployments routinely expose failure modes outside the… 6 arXiv — Machine Learning research 4mo ago GenVid2Robot: From Video Generation to Robot Manipulation via Rigid-Geometric Consistency arXiv:2607.09191v1 Announce Type: cross Abstract: Generated videos provide useful visual motion priors for robot manipulation, but their visual plausibility does not imply physical executability. A generated video usually lacks metric geometry, grasp grounding, robot kinematic… 29 r/MachineLearning community 4mo ago Ph.D. in Operations Research / Big Tech Eng: How to transition into intermediate/advanced ML for high-value industries (Robotics, Defense, Finance)? [D] I hold a Ph.D. in Operations Research, along with a BSc/MSc in Engineering and OR. I previously worked in Big Tech, but I’m currently looking to transition. My primary goal is to upgrade my technical skillset to maximize my industry-related profitability and marketability. I… 32 NVIDIA Developer Blog official-blog 4mo ago How to Evaluate General-Purpose Robot Policies for Real-World Deployment Robotics foundation models have made remarkable progress. Today's best systems can follow natural language instructions to pick, place, sort, and manipulate a... 18 arXiv — Machine Learning research 4mo ago Write-Protected Discrete Bottlenecks for Language-Grounded World Models: A Structural Limitation and Sufficient Fix arXiv:2607.08312v1 Announce Type: new Abstract: How should language interface with a world model's discrete symbol system? The dominant paradigm -- end-to-end injection of LLM/VLM features into robot world models (RT-2, Octo, PaLM-E) -- implicitly assumes that language gradients… 4 Hugging Face Daily Papers research 4mo ago RoboTALES: Learning Reasoning-Guided Robot Policies via Task-Aligned Simulated Futures Abstract RoboTALES introduces a two-stage framework that combines LLM-based planning and VLM-based criticism to improve task-aligned video generation and robotic policy training. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Pretrained video generative models are promising… 22 Ars Technica — AI news-outlet 4mo ago Humanoid robots controlled by surgeons did world-first operation on live pigs Preclinical trial is testing the feasibility of humanoid robots in surgery. 17 Hugging Face Daily Papers research 4mo ago OmniTacTune: Policy-Agnostic Real-World RL for Tactile Residual Adaptation of Visual Policies Abstract OmniTacTune enables efficient adaptation of tactile feedback to visual robot policies through a two-stage reinforcement learning approach that improves success rates in contact-rich manipulation tasks. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Visual policies learned… 21 MIT News — AI research 4mo ago Tiny robot boats build floating structures MIT researchers developed FloatForm, a swarm of small aquatic robots that snap together like ants forming a raft, assembling into reconfigurable structures on the water. 35 arXiv — Machine Learning research 4mo ago Does Demand Response Increase Vulnerability to Cyber Attacks by Adversarial Data Modifications? arXiv:2607.06632v1 Announce Type: new Abstract: Adversarial attacks are crafted data manipulations that aim to deteriorate the outcomes of prediction or decision-making algorithms. In the energy systems literature, adversarial attacks have been studied with a focus on problems… 4 arXiv — Machine Learning research 4mo ago Safe Reinforcement Learning using Ideas from Model Predictive Control arXiv:2607.07252v1 Announce Type: new Abstract: Reinforcement learning (RL) enables the synthesis of control policies directly from data, making it highly appealing for complex cyber-physical systems (CPSs) and robotics. A persistent challenge, however, is ensuring strict, hard… 16 arXiv — NLP / Computation & Language research 4mo ago Multimodal Voice Activity Projection for Turn-Taking in Social Robots with Voice-Activity-Related Pretrained Encoders arXiv:2607.07294v1 Announce Type: cross Abstract: Turn-taking prediction is a key requirement for social robots involved in human-human interaction, particularly in mediator settings, where the robot must anticipate conversational dynamics rather than merely react to pauses.… 23 Hugging Face Daily Papers research 4mo ago RoboDojo: A Unified Sim-and-Real Benchmark for Comprehensive Evaluation of Generalist Robot Manipulation Policies Abstract RoboDojo presents a unified sim-and-real benchmark for evaluating generalist robot manipulation policies across diverse tasks and evaluation dimensions. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Generalist robot manipulation policies have advanced rapidly, yet… 32 Hugging Face Daily Papers research 4mo ago Dual Latent Memory in Vision-Language-Action Models for Robotic Manipulation Abstract LaMem-VLA introduces a latent-memory-native framework that integrates historical experience into vision-language-action reasoning through coordinated memory components operating in the same latent space. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Mainstream… 30 TechCrunch — AI news-outlet 4mo ago This startup thinks robotics is about to have its ChatGPT moment General Intuition is betting millions of hours of video game data can train the foundation models for physical AI, making it easier to build smarter robots with minimal real-world data. 29 r/MachineLearning community 4mo ago LingBot-Video: sparse-MoE video diffusion transformer (13B total, 1.4B active) post-trained as an action-conditioned world model[R] Single-stream diffusion transformer with a DeepSeek-V3-style sparse MoE (128 experts, top-8 routing, 1.4B active of 13B total). Six-reward RL post-training including a physical-plausibility reward, plus an action-to-video mode that predicts robot rollouts from action and… 25 Hugging Face Daily Papers research 4mo ago RynnWorld-4D: 4D Embodied World Models for Robotic Manipulation Abstract A multi-modal 4D world model generates synchronized RGB, depth, and optical flow data from single RGB-D images and language instructions, enabling efficient robotic manipulation through unified diffusion processes and inverse dynamics policy learning. Generated by… 23 Hugging Face Daily Papers research 4mo ago RynnWorld-Teleop: An Action-Conditioned World Model for Digital Teleoperation Abstract Digital teleoperation replaces physical robot interaction with generative world models to create diverse training data for robotics, enabling efficient zero-shot Sim2Real transfer and improved real-world performance. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Scaling… 9 Hacker News — AI on Front Page community 4mo ago Mistral's Robostral Navigate: a state of the art robotics navigation model Article URL: https://mistral.ai/news/robostral-navigate/ Comments URL: https://news.ycombinator.com/item?id=48832212 Points: 230 # Comments: 55 18 Hugging Face Daily Papers research 4mo ago From Foundation to Application: Improving VLA Models in Practice Abstract LingBot-VLA 2.0 enhances generalization across tasks and embodiments through expanded data preprocessing and training on diverse robot configurations, extends action space to include whole-body degrees of freedom for complex manipulation tasks, and incorporates… 32 Hugging Face Daily Papers research 4mo ago 3D HAMSTER: Bridging Planning and Control in Hierarchical Vision Language Action Models through 3D Trajectory Guidance Abstract 3D HAMSTER framework enhances robot manipulation by integrating a vision-language model with depth encoding to generate metrically accurate 3D trajectories for point cloud-based control policies. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Hierarchical… 27 arXiv — Machine Learning research 4mo ago Deep Reinforcement Learning for Dynamic Battery Management of Autonomous Order Pickers arXiv:2607.05683v1 Announce Type: new Abstract: Battery charging of Autonomous Mobile Robots (AMRs) in warehouses is a critical operational challenge that heavily impacts both order processing times and throughput. In this study, we address the dynamic AMR charging problem under… 21 Hugging Face Daily Papers research 4mo ago GaP: A Graph-as-Policy Multi-Agent Self-Learning Harness For Variational Automation Tasks Abstract Graph-as-Policy system combines modular robot skills with multi-agent coding to improve reliability in variable automation tasks through parallel simulation refinement. Generated by Qwen/Qwen2.5-Coder-32B-Instruct For robots to work reliably in commercial and industrial… 32 NVIDIA Developer Blog official-blog 4mo ago Develop Humanoid Robot Policies End-to-End with NVIDIA Isaac GR00T As more teams move from humanoid robot bring-up to task-specific skill development, the need for repeatable development workflows is growing. Building humanoids... 23 Ars Technica — AI news-outlet 4mo ago Robot workers rising: How AI may drive general-purpose autonomy in robotics Top robotics researchers and founders explain how robot autonomy is evolving. 20 Ars Technica — AI news-outlet 4mo ago How AI could enable autonomous robot workers in workplaces—and maybe homes Top robotics researchers and founders explain how robot autonomy is evolving. 7 Hugging Face Daily Papers research 4mo ago InternVLA-A1.5: Unifying Understanding, Latent Foresight, and Action for Compositional Generalization Abstract InternVLA-A1.5 integrates pretrained vision-language models with future prediction in latent space to enable efficient robot manipulation with preserved semantics and long-horizon execution. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Unified models for robot… 15 Hugging Face Daily Papers research 4mo ago EVA-Client: A Unified Data Collection, Inference, and Deployment Framework for Embodied Policies on Real Robots Abstract EVA-Client is an open-source framework that unifies real-robot policy deployment, data collection, and evaluation through a component-decoupled architecture with inspectable execution workflows. Generated by Qwen/Qwen2.5-Coder-32B-Instruct We present EVA-Client, an… 22 Hugging Face Daily Papers research 4mo ago Deform360: A Massive Multi-view Visuotactile Dataset for Deformable World Models Abstract A large-scale visuotactile dataset called Deform360 is introduced to study deformable object dynamics, enabling comparison between 2D video and 3D particle world models for robotic manipulation tasks. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Predicting object… 23 Hugging Face Daily Papers research 4mo ago Vision Pretraining for Dense Spatial Perception Abstract Boundary modeling enables dense spatial perception by learning sub-pixel representations that enhance depth estimation and support embodied AI applications. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Dense spatial perception is essential for physical intelligence,… 13 Hugging Face Daily Papers research 4mo ago GigaWorld-1: A Roadmap to Build World Models for Robot Policy Evaluation Abstract World models for robotic policy evaluation are systematically studied through a new benchmark, revealing that long-horizon rollout consistency and robot-specific controllability are more important than short-term visual realism for reliable policy assessment. Generated… 22 Hugging Face official-blog 4mo ago LeRobot v0.6.0: Imagine, Evaluate, Improve Back to Articles a]:hidden"> LeRobot v0.6.0: Imagine, Evaluate, Improve Published July 7, 2026 Update on GitHub Upvote 1 Steven Palma imstevenpmwork Pepijn Kooijmans pepijn223 Caroline Pascal CarolinePascal Khalil Meftah lilkm Martino Russi nepyope Nikodem Bartnik nikodembartnik… 26 r/LocalLLaMA community 4mo ago GitHub - kallewoof/tftf: Transforming Transformers -- ultra light-weight pipeline for enormous transformer model manipulation with minimal overhead Working with large models that don't fit in your VRAM+RAM is extremely annoying when you want to do things like LoRA merging or converting between formats, so I started the tftf (transforming transformers) project. The idea is simple: do all operations on a per tensor level.… 20 Hugging Face Daily Papers research 4mo ago VLA-Corrector: Lightweight Detect-and-Correct Inference for Adaptive Action Horizon Abstract VLA-Corrector addresses limitations of action chunking in vision-language-action models by introducing a lightweight latent-space vision monitor that enables adaptive corrective replanning, improving robustness in contact-rich manipulation tasks. Generated by… 26 Hugging Face Daily Papers research 4mo ago Embodied.cpp: A Portable Inference Runtime of Embodied AI Models on Heterogeneous Robots Abstract Embodied.cpp is a portable C++ runtime that enables efficient deployment of vision-language-action and world-action models across heterogeneous edge devices through modular execution layers and optimized inference. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Embodied… 7 r/MachineLearning community 4mo ago Question regarding Xournal++ and software 4 taking university notes during class [D] Hi. I have a question, could this plan and pipeline work?. I will be attending university master's classes on AI (thankfully got accepted a few days ago) and computers in a few months. There will be university lectures on machine learning, computer vision, robotics, video games… 9 Hugging Face Daily Papers research 4mo ago Learning to Move Before Learning to Do: Task-Agnostic pretraining for VLAs Abstract Task-Agnostic Pretraining framework trains robotic models using self-supervised inverse dynamics on unlabeled data followed by lightweight language grounding, achieving superior performance with minimal expert demonstrations. Generated by Qwen/Qwen2.5-Coder-32B-Instruct… 28 arXiv — Machine Learning research 4mo ago Gaming Consensus: Coordinated Manipulation in Crowdsourced Fact-Checking arXiv:2607.01824v1 Announce Type: new Abstract: Crowdsourced fact-checking systems have been adopted by major social media companies such as X, Meta, TikTok and Google with the aim of combating misleading information at scale without relying on centralized editorial control.… 15 arXiv — Machine Learning research 4mo ago Privacy-Preserving and Verifiable Approximate Distributed Coded Computing arXiv:2607.02187v1 Announce Type: new Abstract: Distributed machine learning enables collaborative model training without centralizing data, but it also exposes learning processes to privacy leakage and malicious manipulation. Existing defenses typically address these threats in… 13 arXiv — Machine Learning research 4mo ago QFedAgent: Quantum-Enhanced Personalized Federated Learning for Multi-Agent Activity Recognition arXiv:2607.02426v1 Announce Type: new Abstract: Federated learning (FL) enables collaborative model training across distributed devices without sharing raw data, making it suitable for privacy-sensitive robotic sensing applications. However, multi-agent systems generate… 8 arXiv — NLP / Computation & Language research 4mo ago PhysMani: Physics-principled 3D World Model for Dynamic Object Manipulation arXiv:2607.01938v1 Announce Type: cross Abstract: Manipulating fast and dynamically moving targets in unstructured 3D environments remains challenging for embodied AI. Existing visual-language-action models and world models struggle with accurate 3D geometry and physically… 35 Hugging Face Daily Papers research 4mo ago ASPIRE: Agentic /Skills Discovery for Robotics Abstract ASPIRE is a continual learning system that autonomously develops and refines robot control programs through iterative exploration, achieving superior performance and zero-shot generalization in manipulation and household tasks while enabling sim-to-real transfer.… 12 arXiv — Machine Learning research 4mo ago HydraCollab: Adaptive Collaborative-Perception for Distributed Autonomous Systems arXiv:2607.00191v1 Announce Type: cross Abstract: Collaborative-perception enables multi-robot systems to enhance situational awareness by sharing perceptual information. Existing collaborative-perception systems face an inherent trade-off between communication bandwidth… 22 Hugging Face Daily Papers research 4mo ago ABot-M0.5: Unified Mobility-and-Manipulation World Action Model Abstract ABot-M0.5 is a World Action Model for mobile manipulation that improves performance through temporal granularity alignment, action space disentanglement, and train-test consistency in autoregressive prediction. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Mobile… 16 Hacker News — AI on Front Page community 4mo ago Oomwoo, an open-source robot vacuum you build yourself Article URL: https://makerspet.com/blog/building-an-open-source-robot-vacuum-meet-oomwoo/ Comments URL: https://news.ycombinator.com/item?id=48755005 Points: 241 # Comments: 41 37 Hacker News — AI on Front Page community 4mo ago Weave Robotics launches Isaac 1, a $7,999 home robot with Fall 2026 deliveries https://runtimewire.com/article/weave-robotics-isaac-1-home-... Comments URL: https://news.ycombinator.com/item?id=48750989 Points: 203 # Comments: 288 8 Hugging Face Daily Papers research 4mo ago Play2Perfect: What Matters in Dexterous Play Pretraining for Precise Assembly? Abstract A reinforcement learning framework called Play2Perfect enables sample-efficient robotic assembly tasks by first learning general manipulation skills through playful interaction with diverse objects, then adapting these skills for precise assembly through fine-tuning.… 34 Hugging Face Daily Papers research 4mo ago Goku: A Million-Scale Universal Dataset and Benchmark for Instruction-Based Video Editing Abstract A large-scale video editing dataset and model are introduced that support multi-task and structural manipulations through advanced data synthesis and network architectures. Generated by Qwen/Qwen2.5-Coder-32B-Instruct Existing instruction-based video editing datasets… 38 Page 7 of 10 · 500 articles ← Newer Older →